
About
I am currently a Postdoctoral Researcher in the Department of Automation at Tsinghua University, working with Prof. Yunhao Liu.
My research connects embodied and embedded AI with bio-inspired sensing, focusing on event-based vision and multimodal perception for agile drones and resource-constrained robots.
Prior to this, I received my Ph.D. degree with honor in Computer Science and Engineering from Tsinghua University in 2026, advised by Prof. Xinlei Chen and Prof. Jingao Xu. I was also a jointly cultivated Ph.D. at UC Berkeley, advised by Prof. Liwei Lin. I received my B.Eng. degree with honor in Computer Science and Engineering from Central South University in 2022, advised by Prof. Ju Ren.
News
View all →Our papers EventPrune and WorldVLN were accepted by NeurIPS 2026! These works explore event-guided token pruning and world-model-based drone navigation.
Our paper ELF-Net was accepted by ACM SenSys 2027! This work fuses events and sparse LiDAR for robust depth estimation under low light and fast motion.
Our paper EV-Pose was accepted by IEEE TMC! This work introduces an event-camera-enhanced high-frequency visual positioning service for accurate drone landing.
I received my Ph.D. degree from Tsinghua University and was honored as an Outstanding Graduate of Beijing and Tsinghua University.
x^2-Fusion was accepted by IEEE/CVF CVPR 2026. This work introduces an edge space to bridge Event, Lidar, and Camera modalities for joint scene and optical flow estimation.
Selected Publications
View All →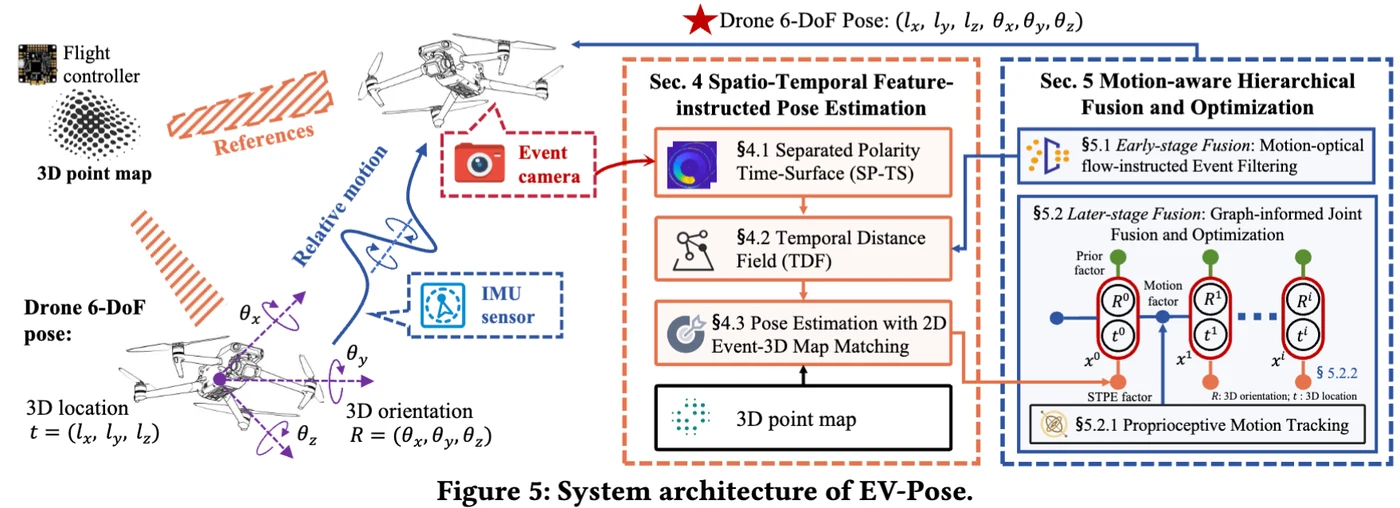
EV-Pose: Event-Camera-Enhanced High-Frequency Visual Positioning Service for Accurate Drone Landing
Haoyang Wang, Xinyu Luo, Wenhua Ding, Jingao Xu, Xuecheng Chen, Ruiyang Duan, Jialong Chen, Chao Wang, Haitao Zhang, Yunhao Liu, Xinlei Chen†
IEEE Transactions on Mobile Computing, 2026
Combines event vision, inertial sensing, and 3D maps for fast, accurate drone pose tracking.
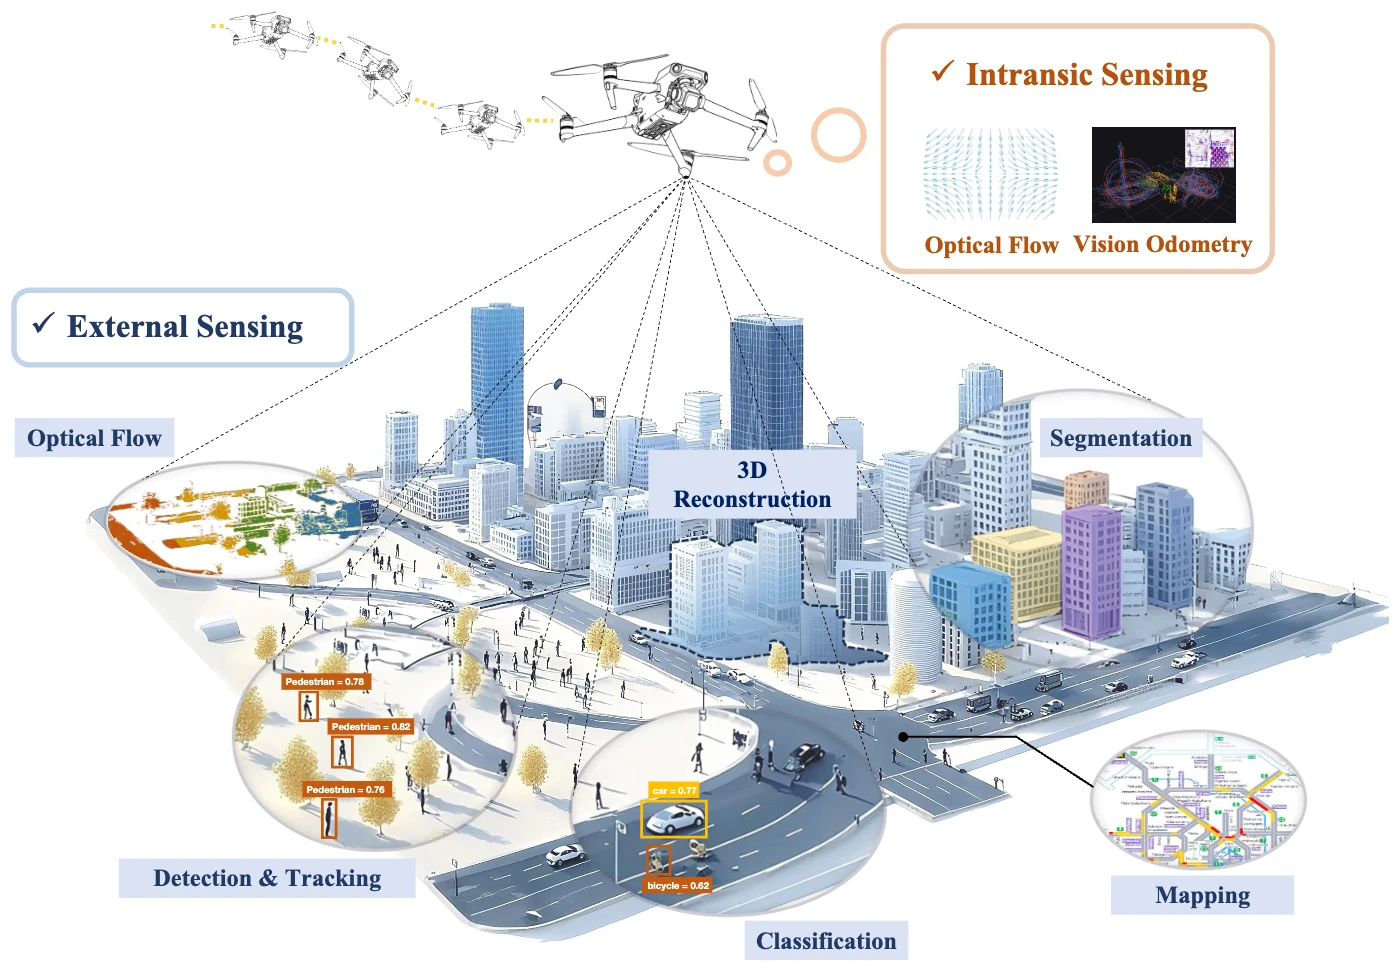
Event Camera Meets Mobile Embodied Perception: Abstraction, Algorithm, Acceleration, Application
Haoyang Wang, Ruishan Guo, Pengtao Ma, Ciyu Ruan, Xinyu Luo, Wenhua Ding, Tianyang Zhong, Jingao Xu, Yunhao Liu, Xinlei Chen†
ACM Computing Survey, 2026
Organizes event-based mobile perception around four pillars: abstraction, algorithms, acceleration, and applications.
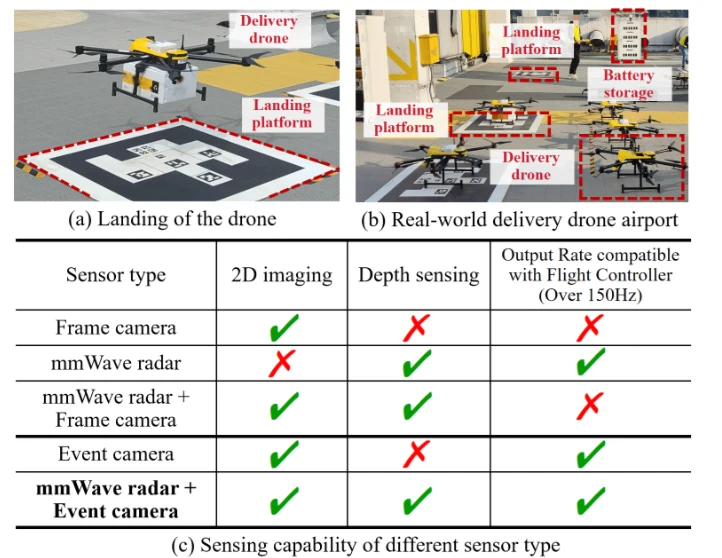
Ultra-High-Frequency Harmony: mmWave Radar and Event Camera Orchestrate Accurate Drone Landing
Haoyang Wang, Jingao Xu, Xinyu Luo, Xuecheng Chen, Ting Zhang, Ruiyang Duan, Yunhao Liu, Xinlei Chen†
ACM SenSys, 2025
Pairs event cameras with mmWave radar for accurate, high-frequency localization during drone landing.
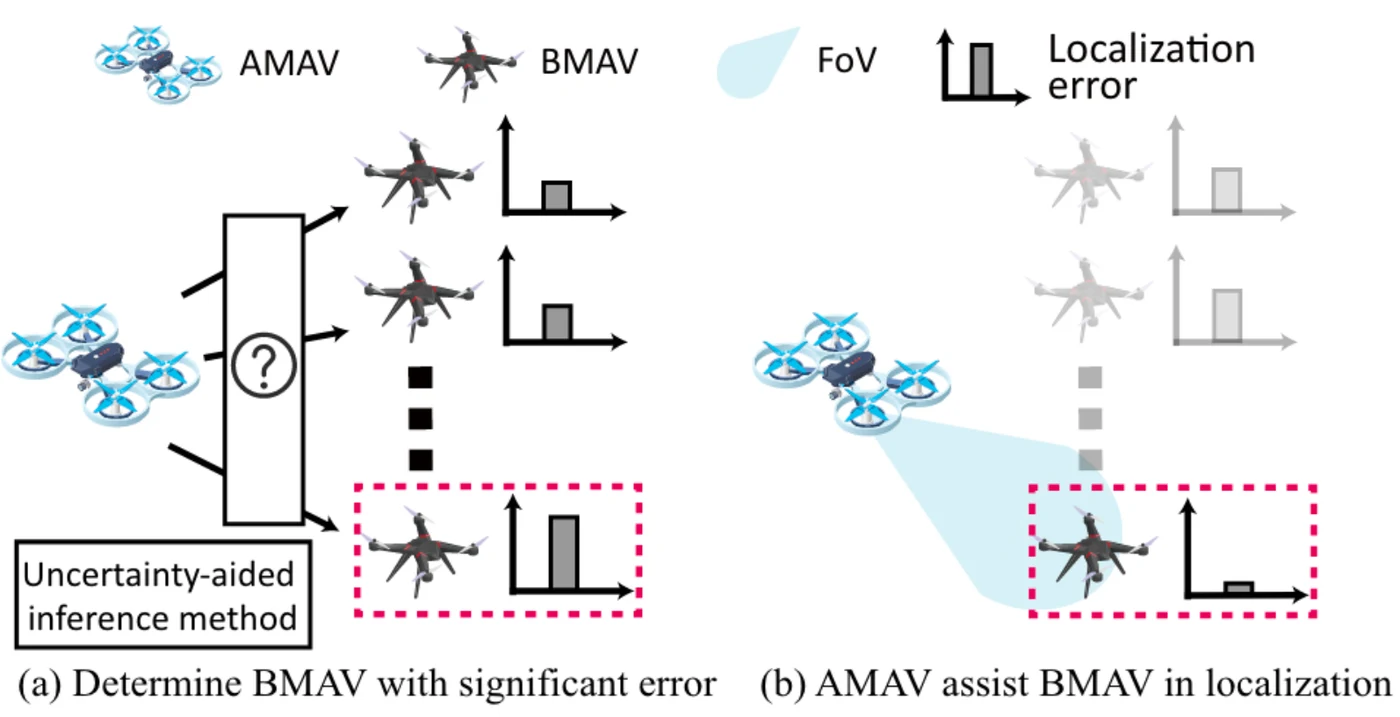
TransformLoc: Transforming MAVs into Mobile Localization Infrastructures in Heterogeneous Swarms
Haoyang Wang, Jingao Xu, Chenyu Zhao, Zihong Lu, Yuhan Cheng, Xuecheng Chen, Xiao-Ping Zhang, Yunhao Liu, Xinlei Chen†
IEEE INFOCOM, 2024
Enables capable drones to provide collaborative localization for resource-limited teammates.
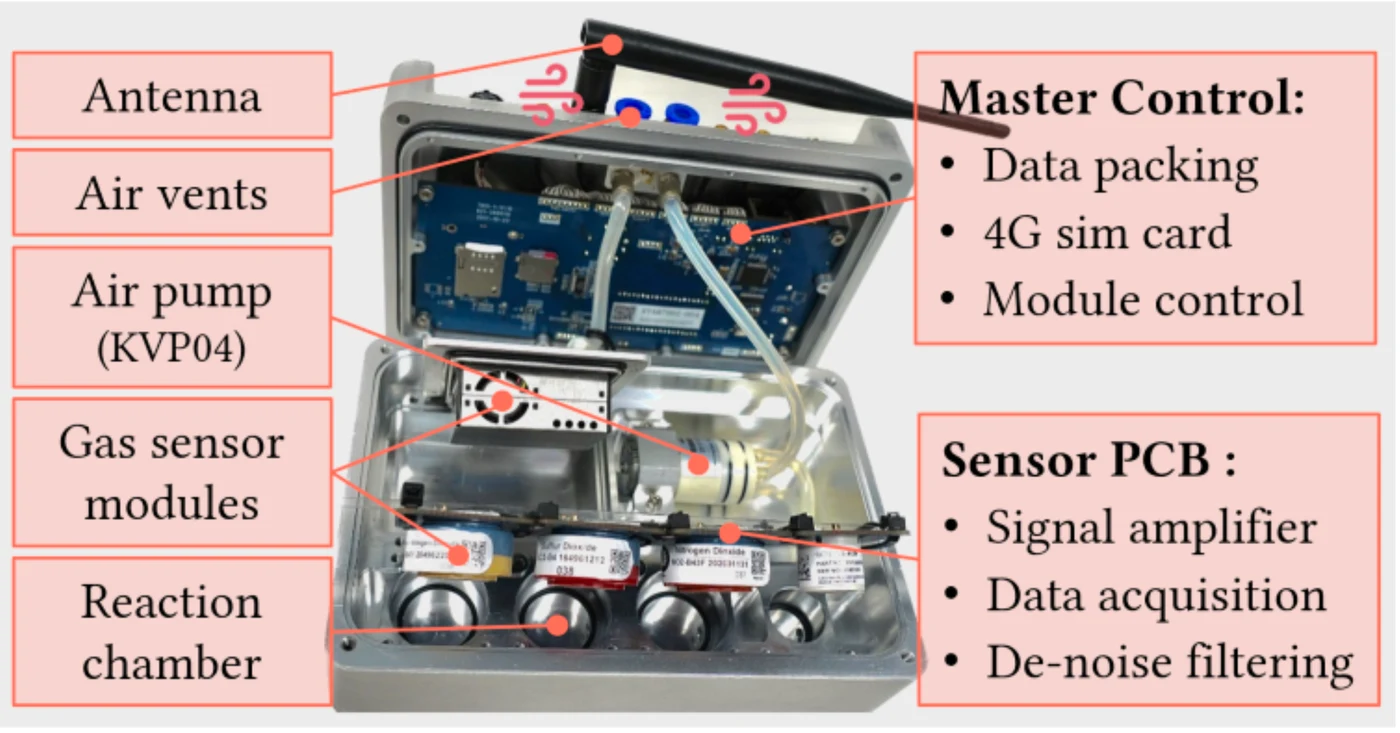
MobiAir: Unleashing Sensor Mobility for City-scale and Fine-grained Air-Quality Monitoring with AirBERT
Yuxuan Liu*, Haoyang Wang*, Fanhang Man, Jingao Xu, Fan Dang, Yunhao Liu, Xiao-Ping Zhang, Xinlei Chen†
ACM MobiSys, 2024
Uses AirBERT to disentangle mixed gas measurements for fine-grained mobile air-quality sensing.
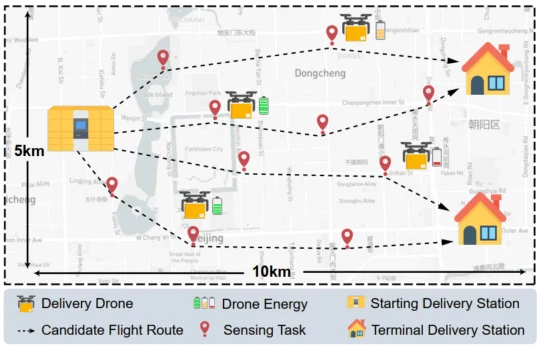
DDL: Empowering Delivery Drones with Large-scale Urban Sensing Capability
Xuecheng Chen*, Haoyang Wang*, Yuhan Cheng, Haohao Fu, Yuxuan Liu, Fan Dang, Yunhao Liu, Xinlei Chen†
IEEE Journal of Selected Topics in Signal Processing, 2024
Jointly schedules deliveries and urban sensing under drone energy and fleet constraints.