Publications
* indicated co-primary authors, † indicated corresponding author.
2027
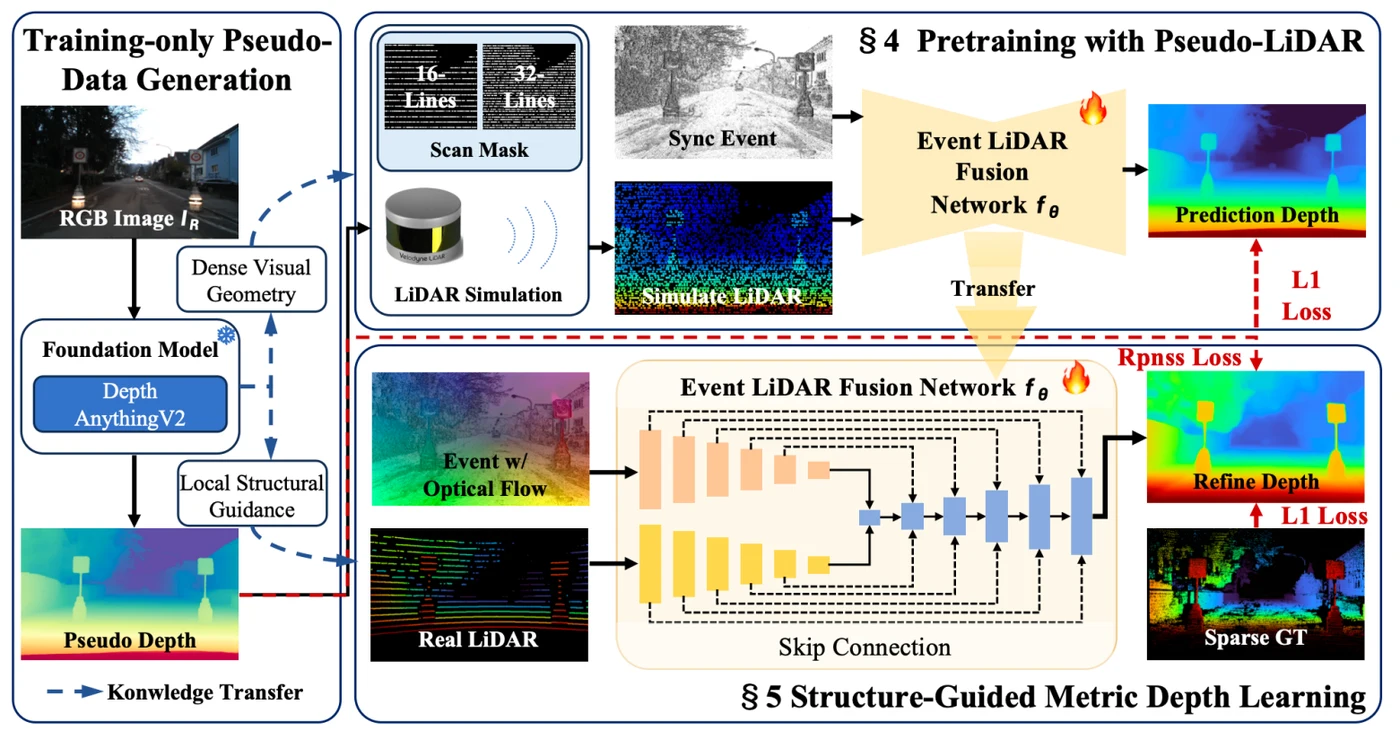
When RGB goes blind: Robust Depth Estimation via Event-LiDAR Fusion
Wenhua Ding, Chi Liu, Shihan Peng, Haoyang Wang, Shilong Ji, Zhengli Zhang, Yude Li, Jingao Xu, Yunhao Liu, Xinlei Chen
ACM SenSys, 2027
Estimates dense depth from events and sparse LiDAR under low light and fast motion.
2026
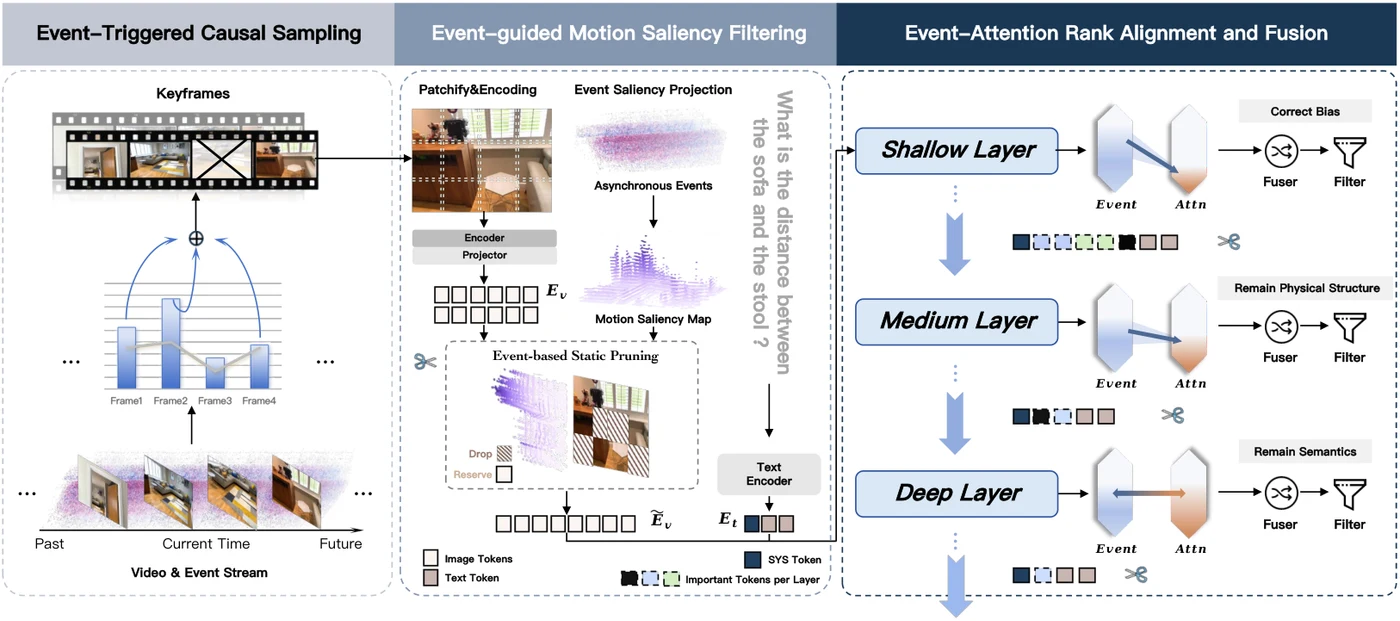
EventPrune: Cascaded Event-Assisted Token Pruning for Efficient First-Person Dynamic Spatial Reasoning
Pengtao Ma, Ziliang Zhou, Ciyu Ruan, Haoyang Wang, Kaiyuan Li, Zihang Gong, Wenhua Ding, Chen Gao, Jingao Xu, Xinlei Chen
NeurIPS, 2026
Uses event motion cues to prune visual tokens while preserving dynamic spatial reasoning.
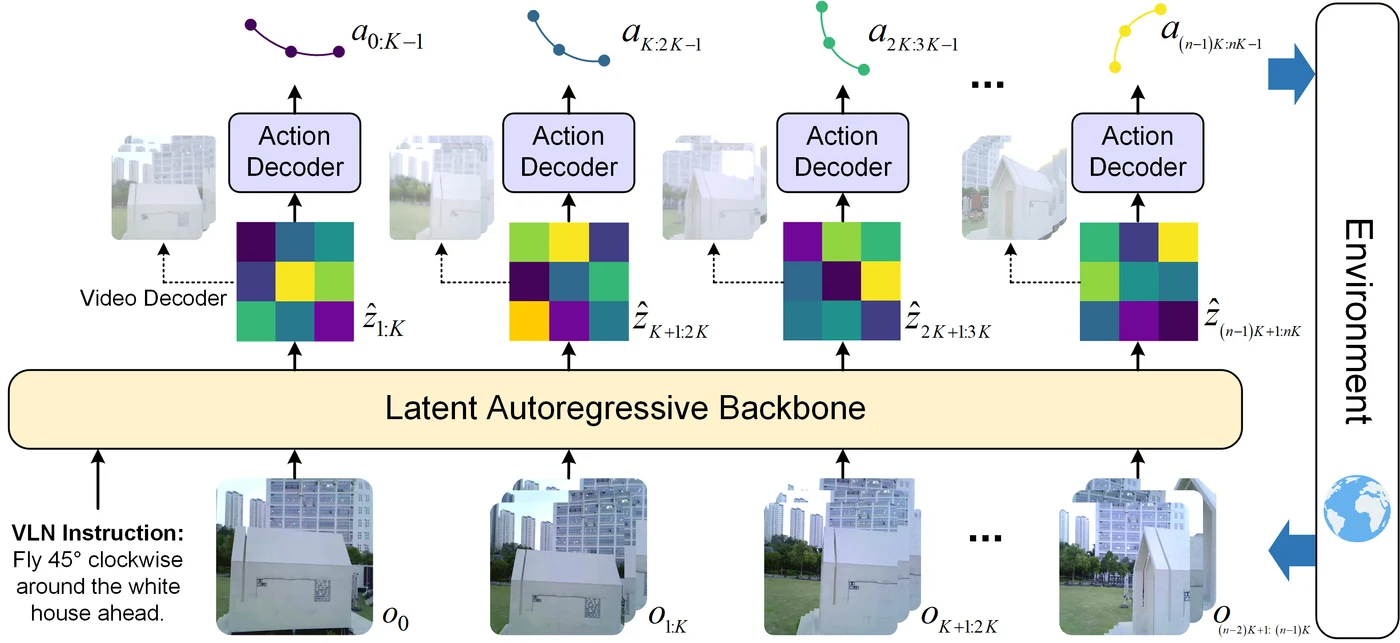
WorldVLN: Autoregressive World Action Model for Aerial Vision-Language Navigation
Baining Zhao, Jiacheng Xu, Weicheng Feng, Xin Zhang, Zhaolu Wang, Haoyang Wang, Shilong Ji, Ziyou Wang, Jianjie Fang, Zhiheng Zheng, Weichen Zhang, Yu Shang, Wei Wu, Chen Gao, Xinlei Chen, Yong Li
NeurIPS, 2026
Predicts future world states and converts them into waypoints for language-guided drone navigation.
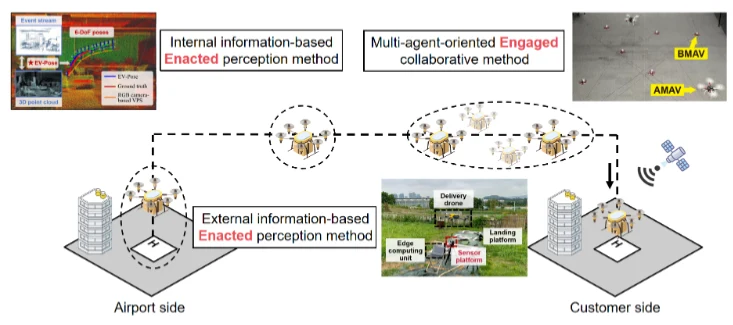
Key Technologies for Low-altitude Intelligent Perception with Bio-inspired Dynamic Vision
Haoyang Wang
Tsinghua University, 2026
Studies bio-inspired dynamic vision for low-altitude perception, from individual drones to collaborative swarms.
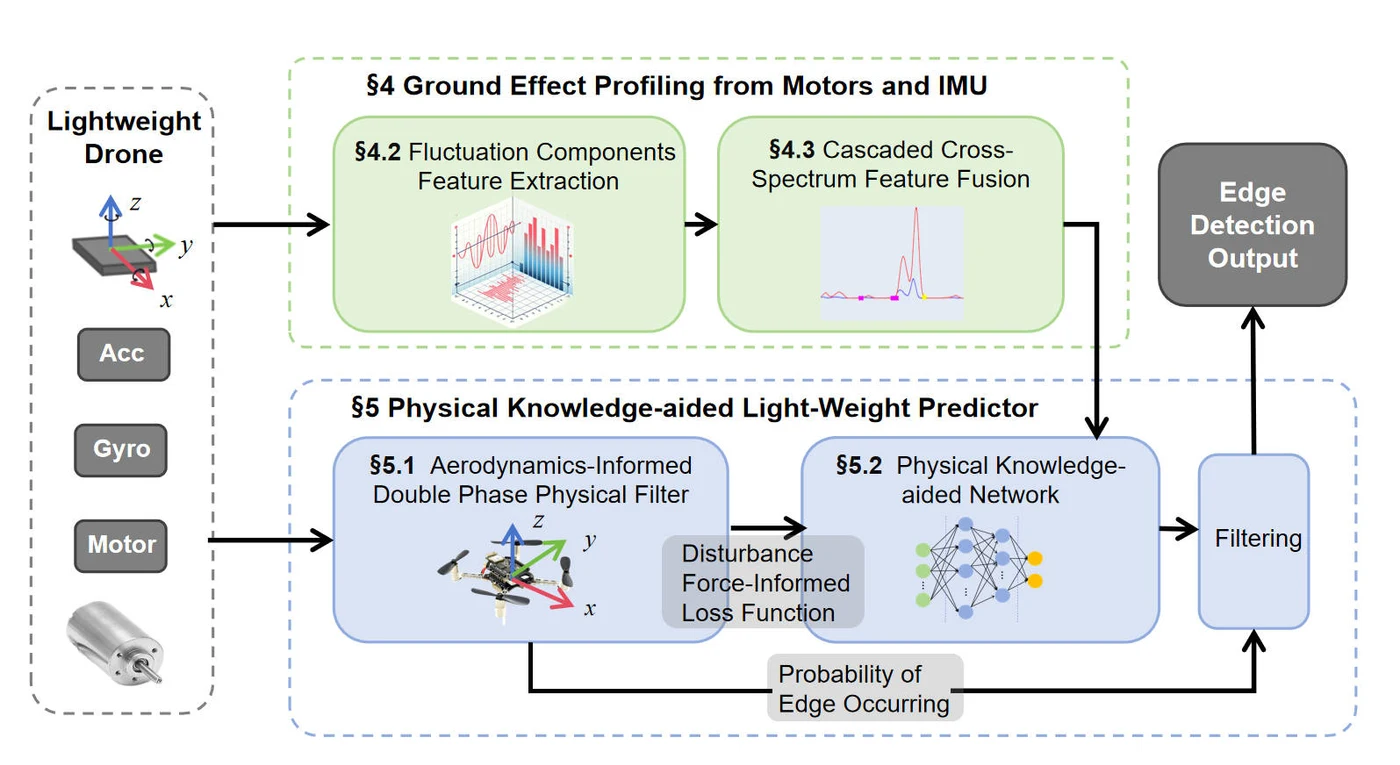
Flight Dynamics to Sensing Modalities: Exploiting Drone Ground Effect for Accurate Edge Detection
Chenyu Zhao*, Ciyu Ruan*, Jingao Xu, Haoyang Wang†, Shengbo Wang, Jiaqi Li, Jirong Zha, Weijie Hong†, Zheng Yang, Yunhao Liu, Xiao-Ping Zhang, Xinlei Chen
IEEE Transactions on Mobile Computing, 2026
Uses drone ground-effect dynamics as a sensing signal for accurate edge detection.
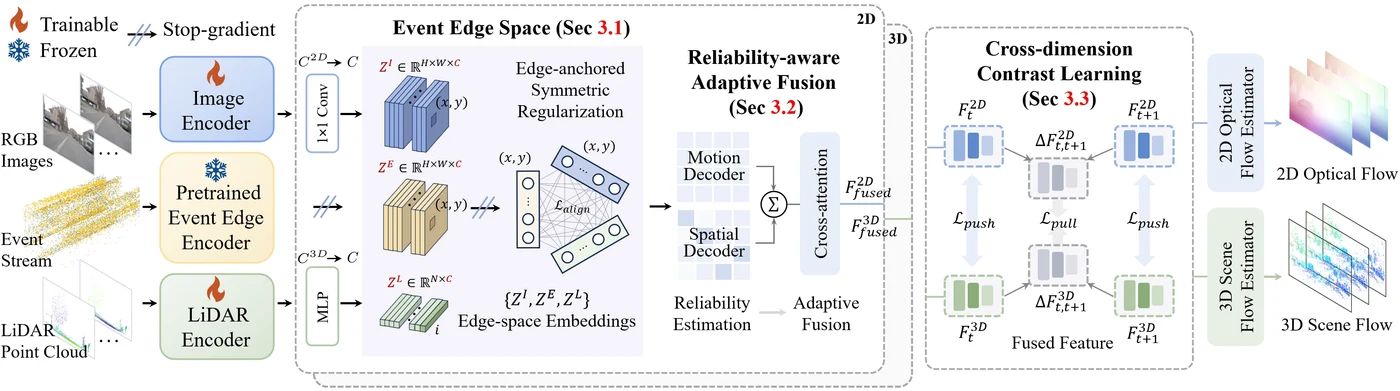
x^2-Fusion: Cross-Modality and Cross-Dimension Flow Estimation in Event Edge Space
Ruishan Guo*, Ciyu Ruan*, Haoyang Wang*, Zihang Gong, Jingao Xu, Xinlei Chen†
IEEE/CVF CVPR Highlight, 2026
Aligns event, image, and LiDAR features in a shared edge space to estimate optical and scene flow.
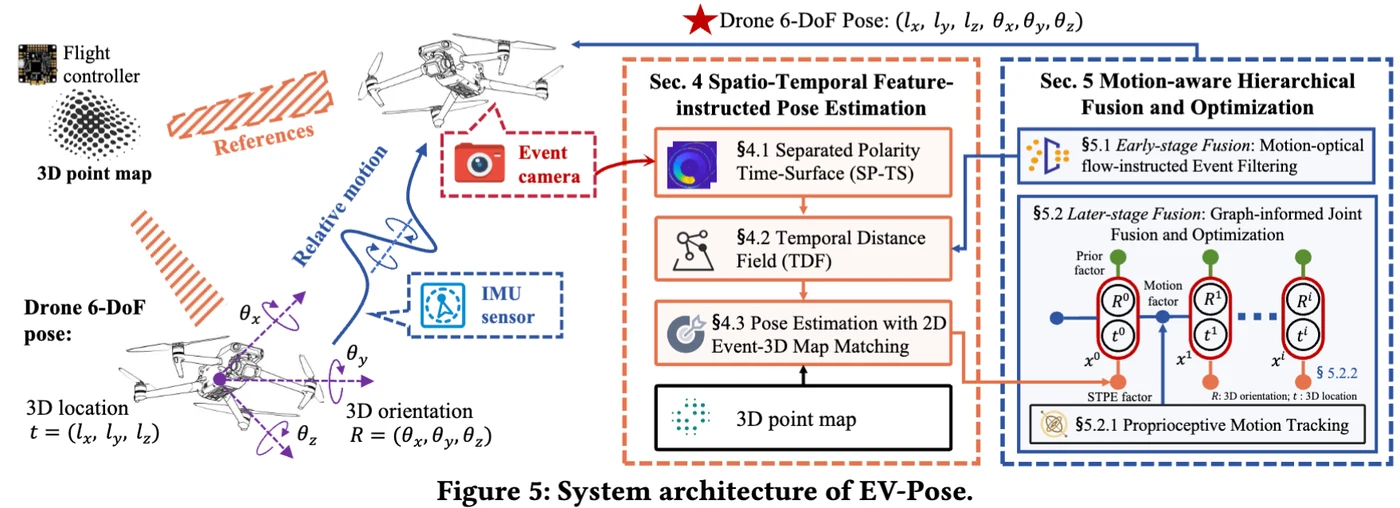
EV-Pose: Event-Camera-Enhanced High-Frequency Visual Positioning Service for Accurate Drone Landing
Haoyang Wang, Xinyu Luo, Wenhua Ding, Jingao Xu, Xuecheng Chen, Ruiyang Duan, Jialong Chen, Chao Wang, Haitao Zhang, Yunhao Liu, Xinlei Chen†
IEEE Transactions on Mobile Computing, 2026
Combines event vision, inertial sensing, and 3D maps for fast, accurate drone pose tracking.
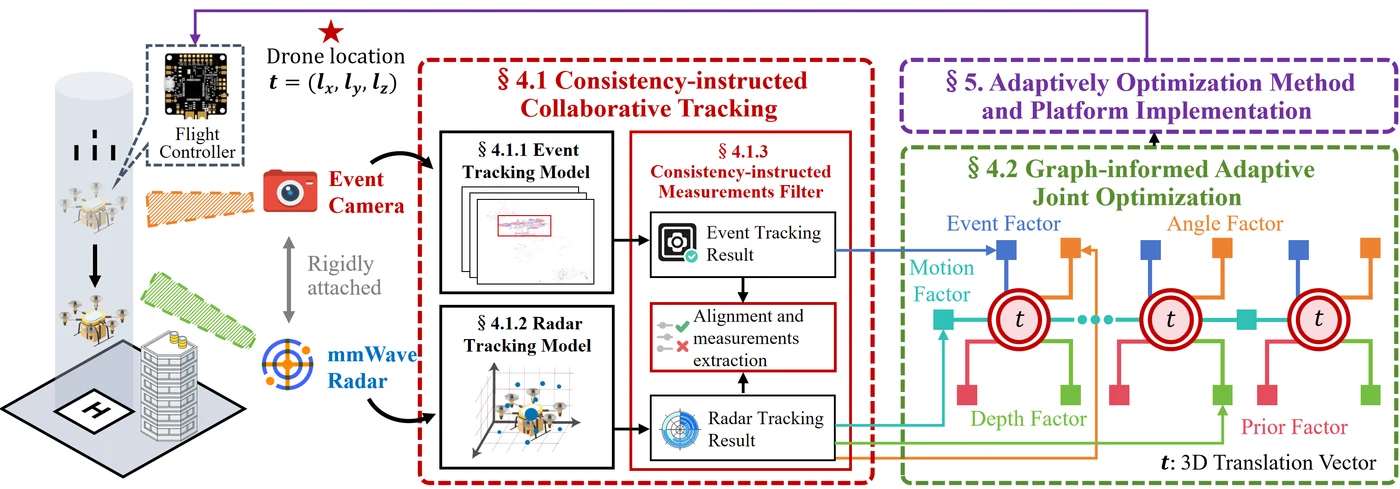
mmE-Loc: Facilitating Accurate Drone Landing with Ultra-High-Frequency Localization
Haoyang Wang, Jingao Xu, Xinyu Luo, Ting Zhang, Xuecheng Chen, Ruiyang Duan, Jialong Chen, Yunhao Liu, Jianfeng Zheng, Weijie Hong, Xinlei Chen†
IEEE Transactions on Mobile Computing, 2026
Fuses event cameras and mmWave radar for precise, low-latency drone landing.
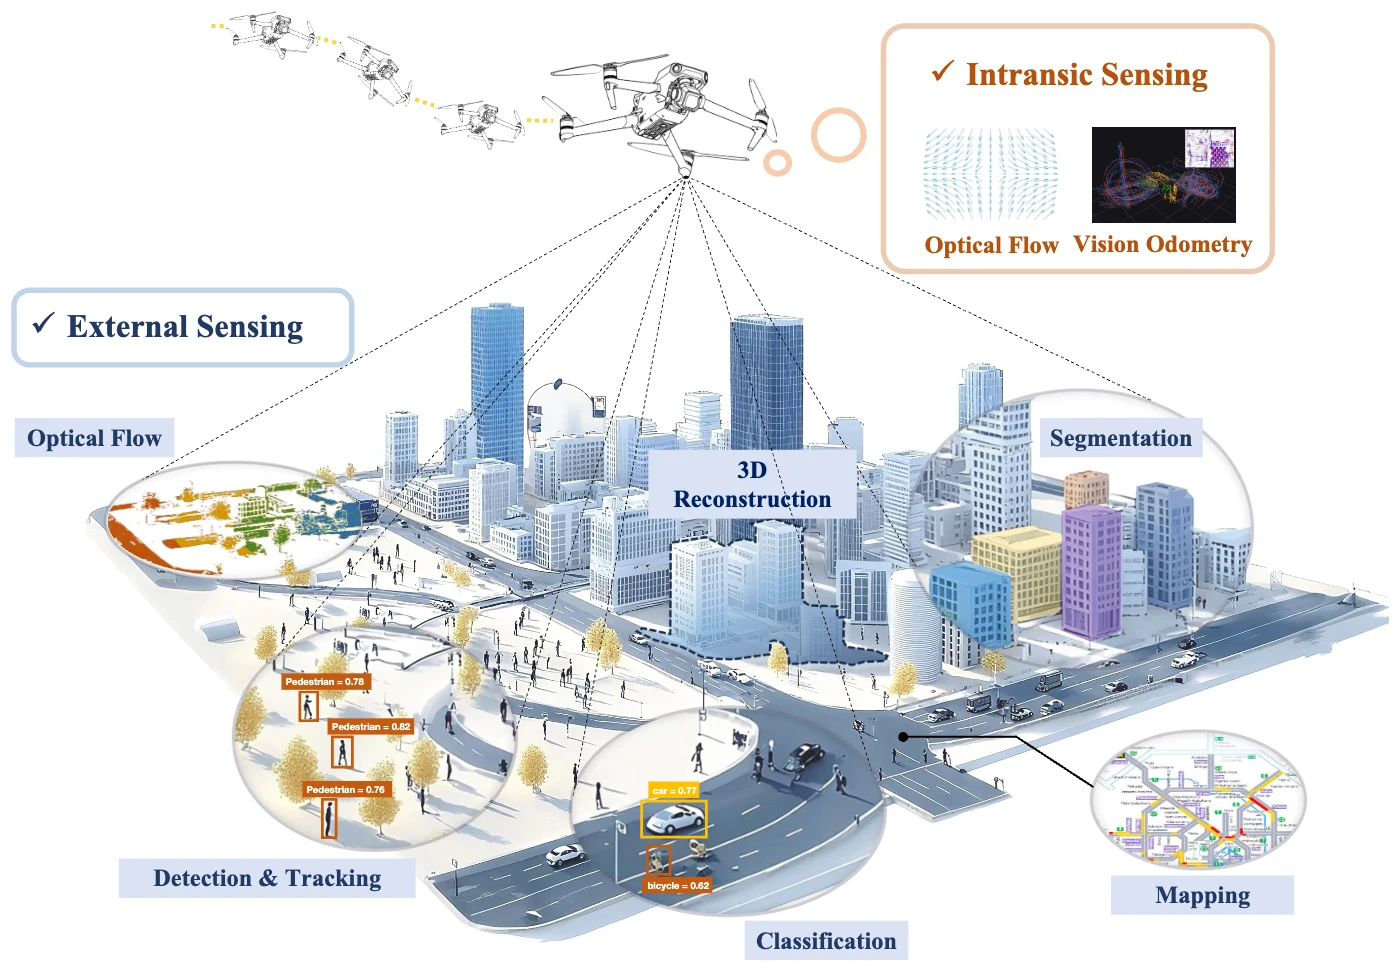
Event Camera Meets Mobile Embodied Perception: Abstraction, Algorithm, Acceleration, Application
Haoyang Wang, Ruishan Guo, Pengtao Ma, Ciyu Ruan, Xinyu Luo, Wenhua Ding, Tianyang Zhong, Jingao Xu, Yunhao Liu, Xinlei Chen†
ACM Computing Survey, 2026
Organizes event-based mobile perception around four pillars: abstraction, algorithms, acceleration, and applications.
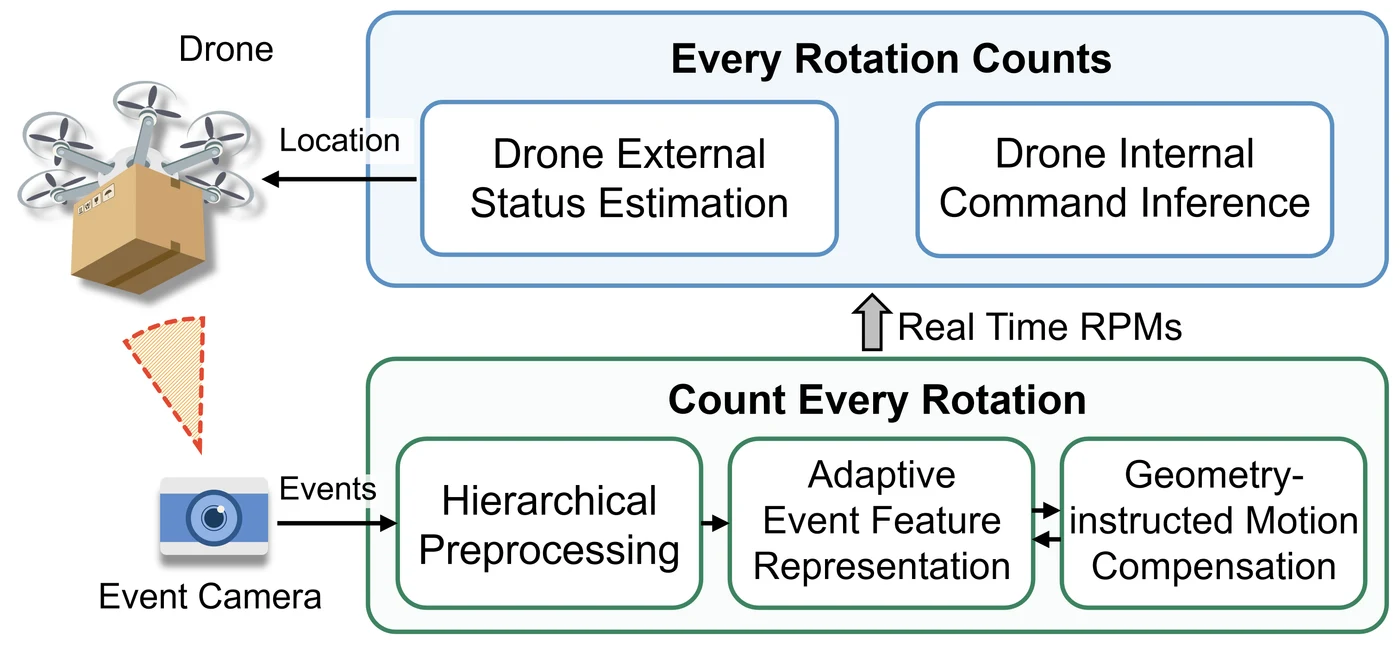
Count Every Rotation and Every Rotation Counts: Exploring Drone Dynamics via Propeller Sensing
Xuecheng Chen*, Jingao Xu*, Wenhua Ding, Haoyang Wang, Xinyu Luo, Ruiyang Duan, Jialong Chen, Xueqian Wang, Yunhao Liu, Xinlei Chen†
ACM SenSys, 2026
Measures propeller rotation with event cameras to infer drone dynamics without physical contact.
2025
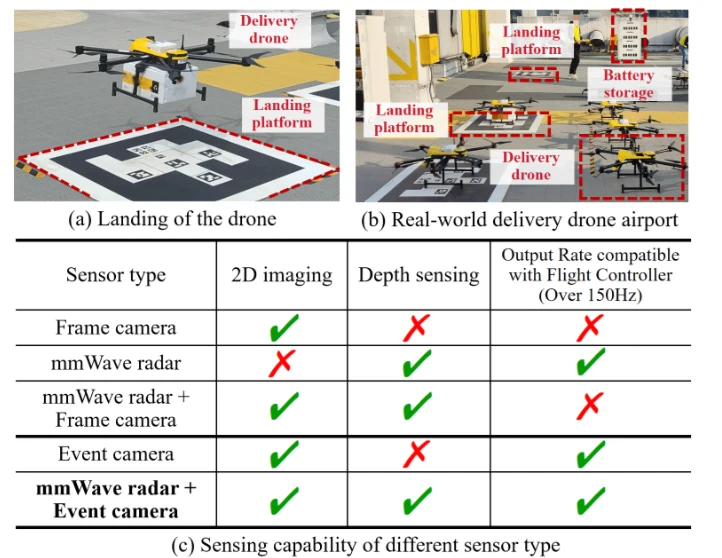
Ultra-High-Frequency Harmony: mmWave Radar and Event Camera Orchestrate Accurate Drone Landing
Haoyang Wang, Jingao Xu, Xinyu Luo, Xuecheng Chen, Ting Zhang, Ruiyang Duan, Yunhao Liu, Xinlei Chen†
ACM SenSys, 2025
Pairs event cameras with mmWave radar for accurate, high-frequency localization during drone landing.
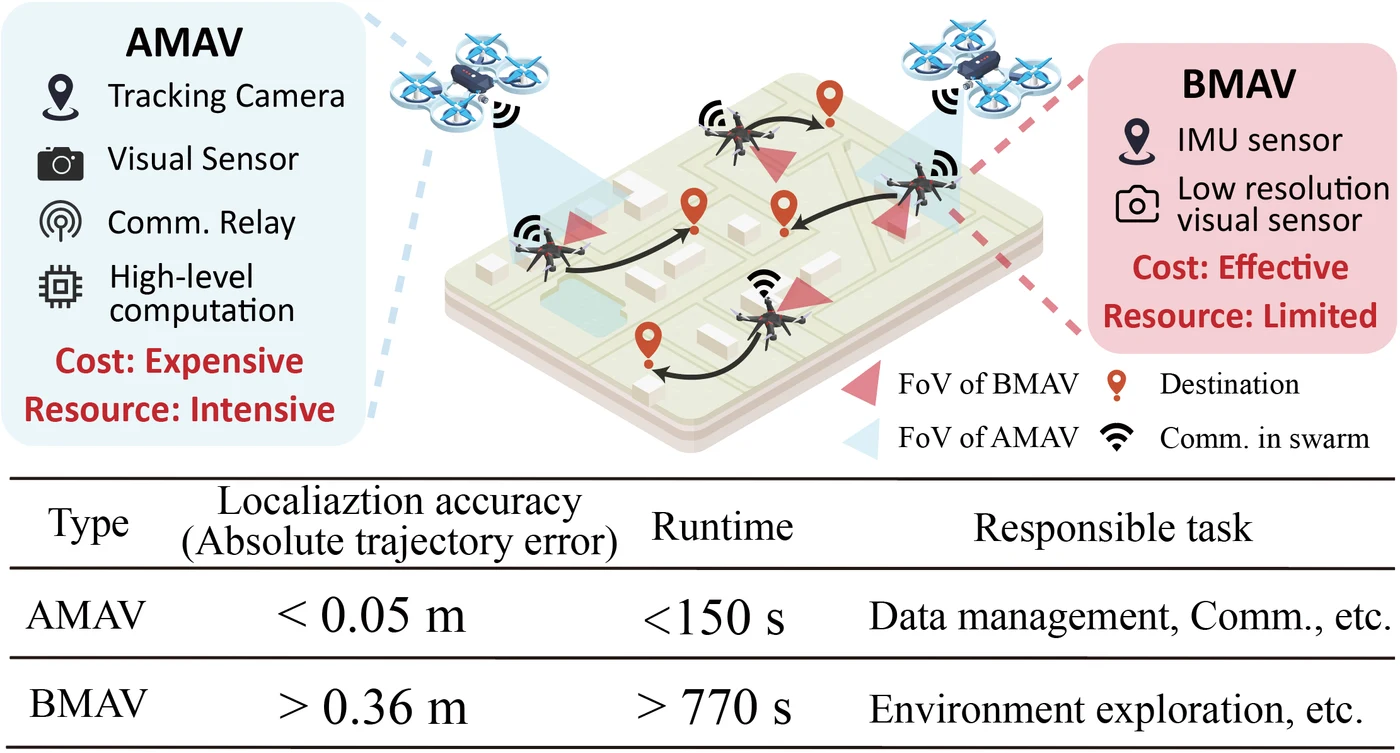
Aerial Shepherds: Enabling Hierarchical Localization in Heterogeneous MAV Swarms
Haoyang Wang, Jingao Xu, Chenyu Zhao, Yuhan Cheng, Xuecheng Chen, Chaopeng Hong, Xiao-Ping Zhang, Yunhao Liu, Xinlei Chen†
IEEE Transactions on Mobile Computing, 2025
Turns capable drones into mobile localization infrastructure for lightweight teammates.
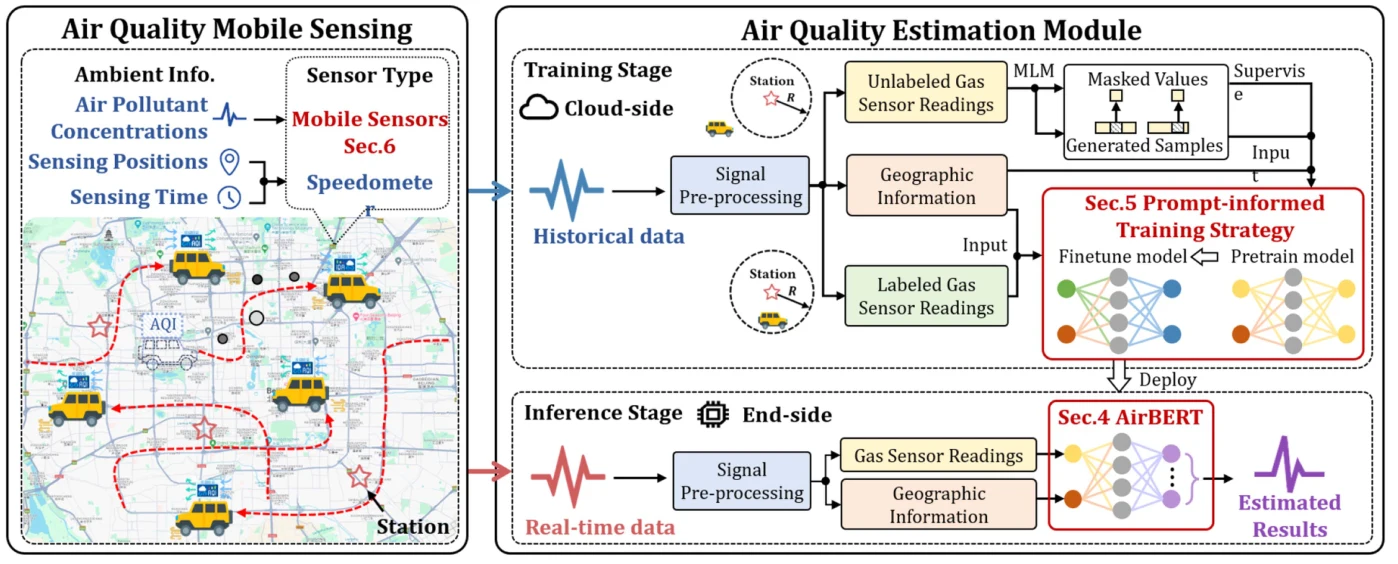
CatUA: Catalyzing Urban Air Quality Intelligence through Mobile Crowd-sensing
Nan Zhou*, Yuxuan Liu*, Haoyang Wang*, Fanhang Man, Jingao Xu, Fan Dang, Chaopeng Hong, Yunhao Liu, Xiao-Ping Zhang, Yali Song, Qiuhua Wang, Xinlei Chen†
IEEE Transactions on Mobile Computing, 2025
Combines AirBERT with prompt-informed training to recover accurate air-quality measurements from mobile sensors.
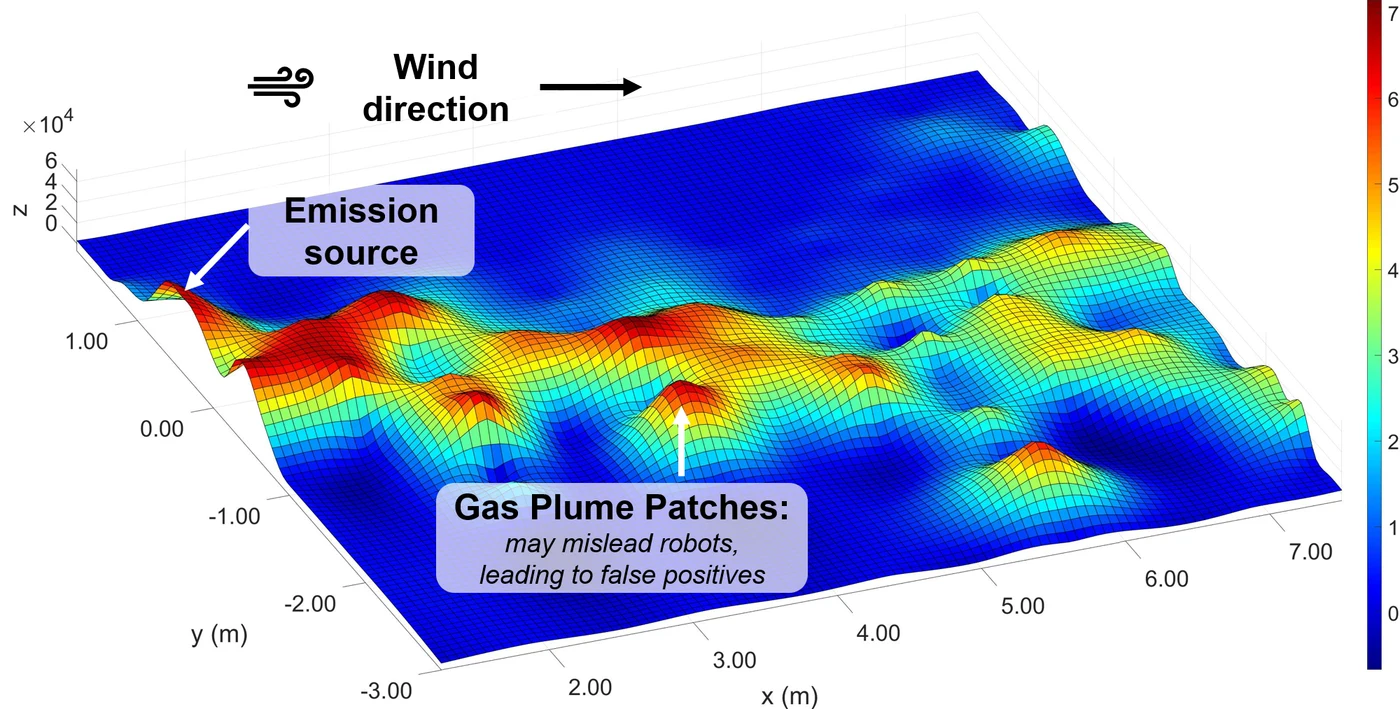
SniffySquad: Patchiness-Aware Gas Source Localization with Multi-Robot Collaboration
Yuhan Cheng, Xuecheng Chen, Yixuan Yang, Haoyang Wang, Jingao Xu, Chaopeng Hong, Xiao-Ping Zhang, Yunhao Liu, Xinlei Chen†
ACM Transactions on Sensor Networks, 2025
Coordinates robot sensing and roles to locate gas sources in patchy, real-world plumes.
2024
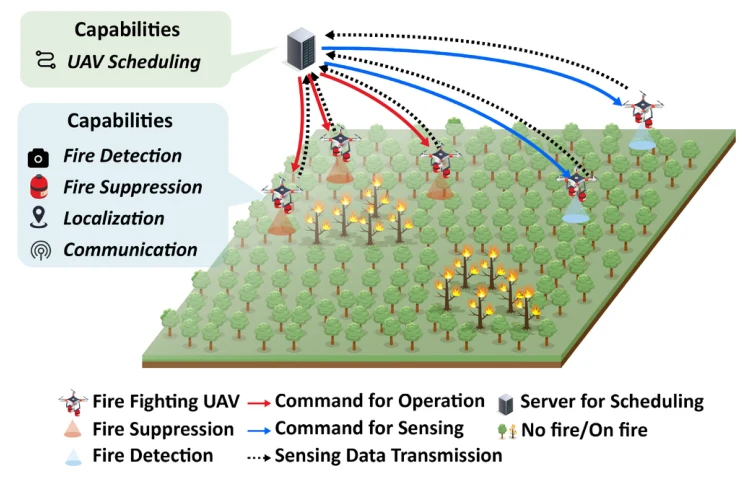
Soscheduler: Toward proactive and adaptive wildfire suppression via multi-uav collaborative scheduling
Xuecheng Chen, Zijian Xiao, Yuhan Cheng, Chen-Chun Hsia, Haoyang Wang, Jingao Xu, Susu Xu, Fan Dang, Xiao-Ping Zhang, Yunhao Liu, others
IEEE Internet of Things Journal, 2024
Coordinates multiple drones through proactive and adaptive scheduling for wildfire suppression.
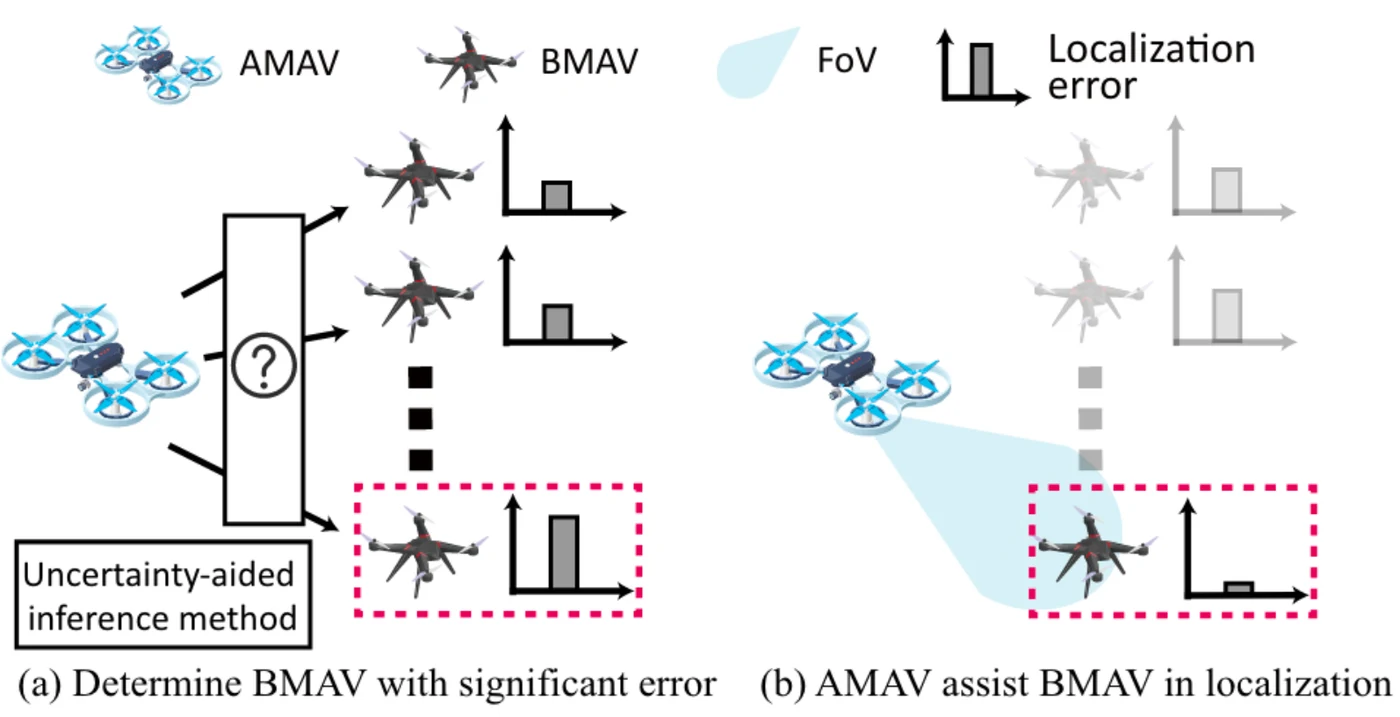
TransformLoc: Transforming MAVs into Mobile Localization Infrastructures in Heterogeneous Swarms
Haoyang Wang, Jingao Xu, Chenyu Zhao, Zihong Lu, Yuhan Cheng, Xuecheng Chen, Xiao-Ping Zhang, Yunhao Liu, Xinlei Chen†
IEEE INFOCOM, 2024
Enables capable drones to provide collaborative localization for resource-limited teammates.
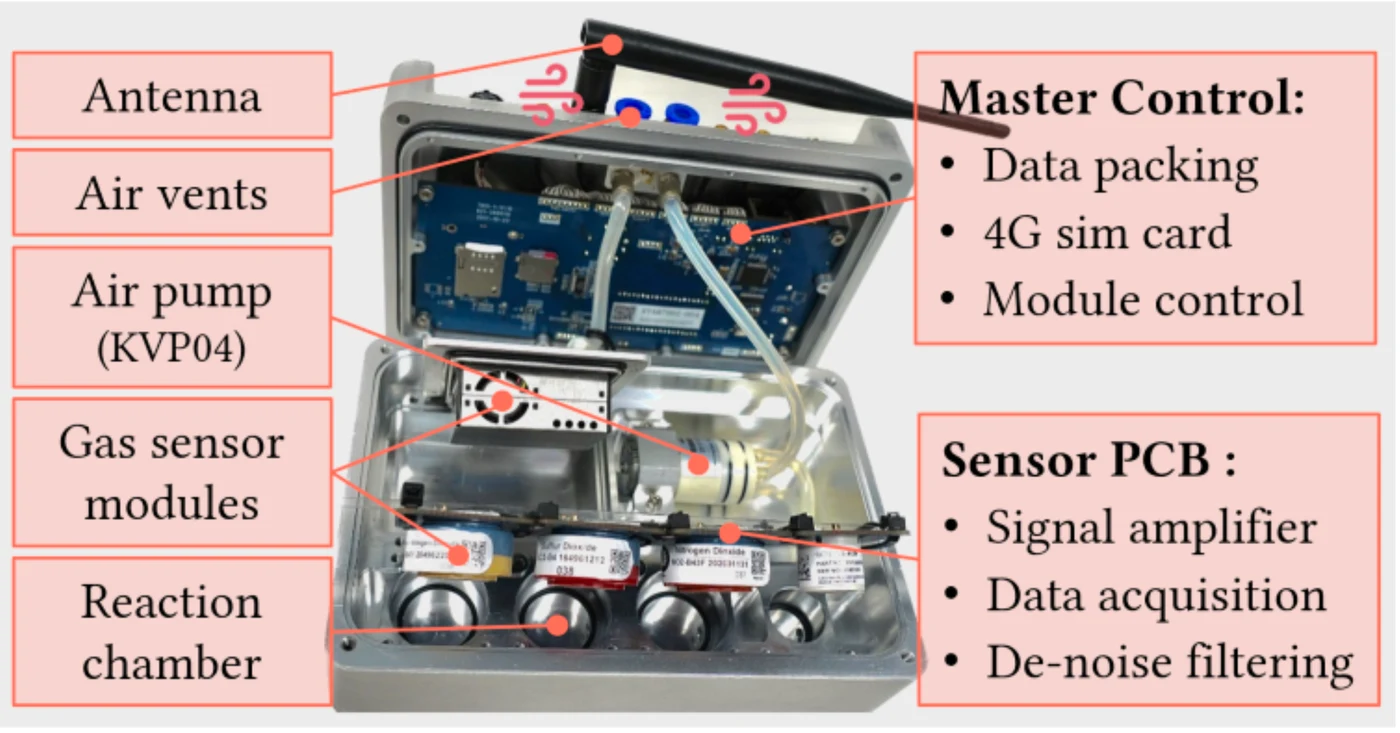
MobiAir: Unleashing Sensor Mobility for City-scale and Fine-grained Air-Quality Monitoring with AirBERT
Yuxuan Liu*, Haoyang Wang*, Fanhang Man, Jingao Xu, Fan Dang, Yunhao Liu, Xiao-Ping Zhang, Xinlei Chen†
ACM MobiSys, 2024
Uses AirBERT to disentangle mixed gas measurements for fine-grained mobile air-quality sensing.
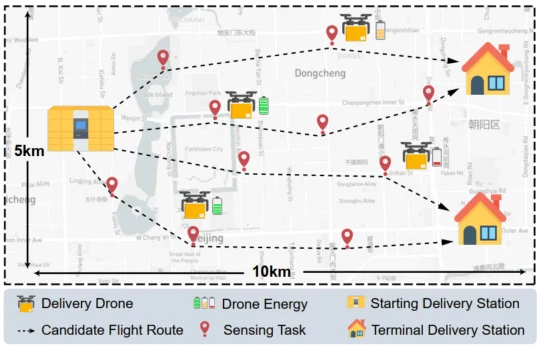
DDL: Empowering Delivery Drones with Large-scale Urban Sensing Capability
Xuecheng Chen*, Haoyang Wang*, Yuhan Cheng, Haohao Fu, Yuxuan Liu, Fan Dang, Yunhao Liu, Xinlei Chen†
IEEE Journal of Selected Topics in Signal Processing, 2024
Jointly schedules deliveries and urban sensing under drone energy and fleet constraints.
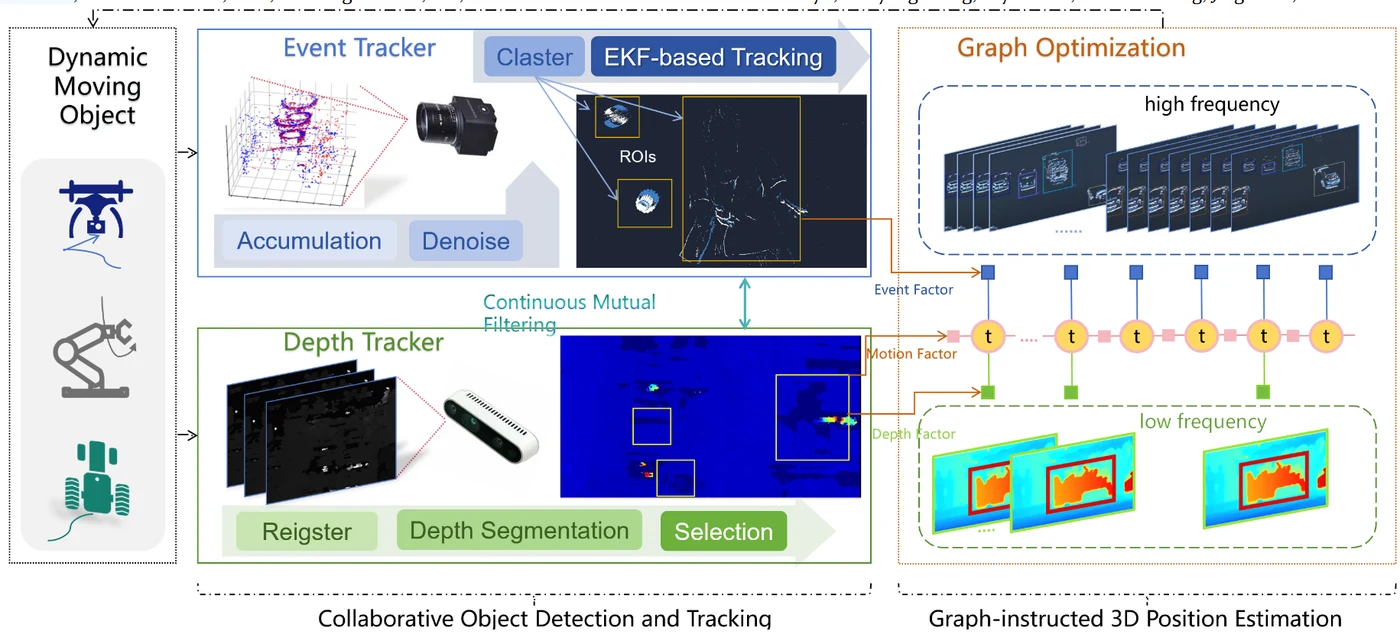
EventTracker: 3D Localization and Tracking of High-Speed Object with Event and Depth Fusion
Xinyu Luo, Haoyang Wang, Ciyu Ruan, Chenxin Liang, Jingao Xu, Xinlei Chen†
ACM MobiCom Picasso Workshop, 2024
Fuses event and depth measurements to localize and track fast-moving objects in 3D.
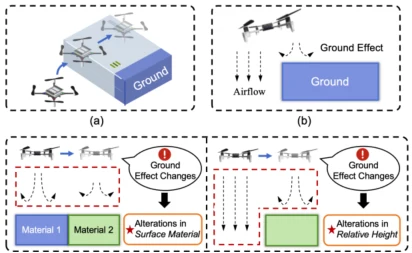
Foes or Friends: Embracing Ground Effect for Edge Detection on Lightweight Drones
Chenyu Zhao*, Ciyu Ruan*, Jingao Xu, Haoyang Wang, Shengbo Wang, Jiaqi Li, Jirong Zha, Zheng Yang, Yunhao Liu, Xiao-Ping Zhang, Xinlei Chen†
ACM MobiCom, 2024
Turns ground effect into a sensing capability for edge detection on lightweight drones.
2023
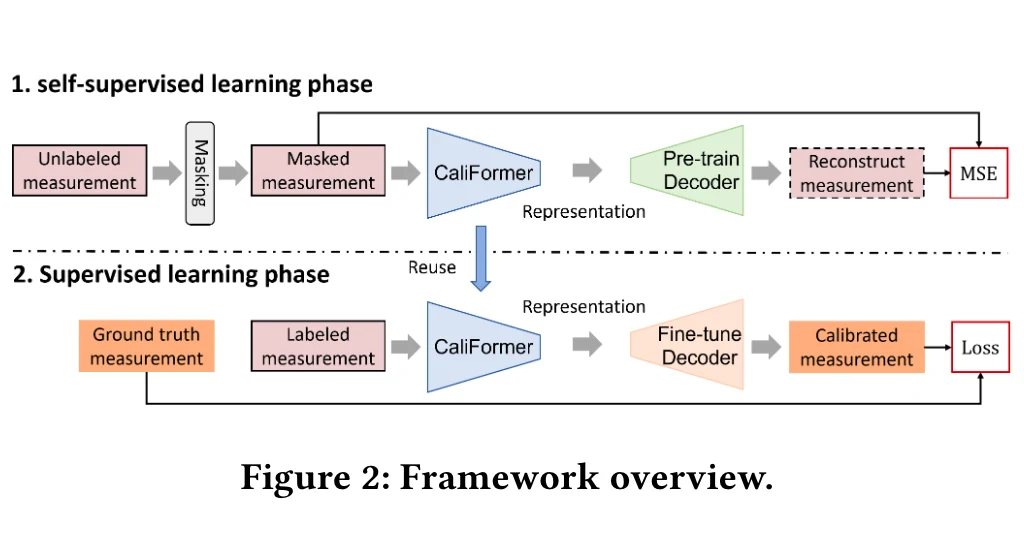
Califormer: Leveraging unlabeled measurements to calibrate sensors with self-supervised learning
Haoyang Wang*, Yuxuan Liu*, Chenyu Zhao, Jiayou He, Wenbo Ding, Xinlei Chen†
ACM UbiComp CPD, 2023
Calibrates sensors from unlabeled measurements using self-supervised learning.
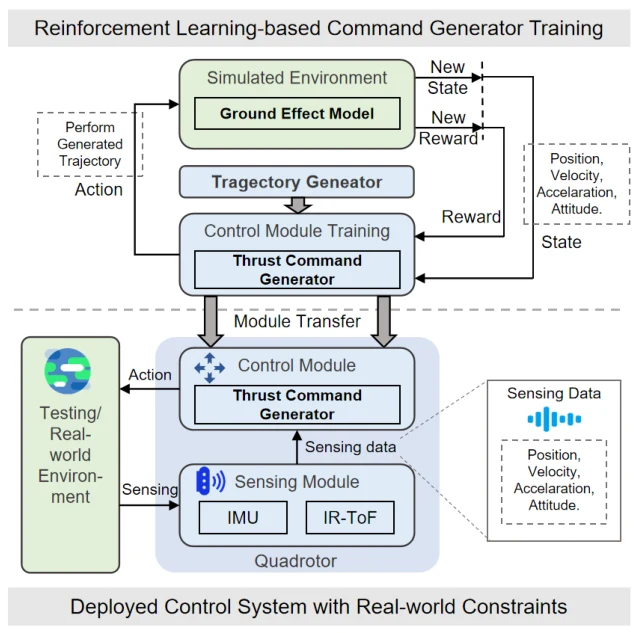
SmoothLander: A Quadrotor Landing Control System with Smooth Trajectory Guarantee Based on Reinforcement Learning
Chenyu Zhao*, Haoyang Wang*, Jiaqi Li, Fanhang Man, Shilong Mu, Wenbo Ding, Xiao-Ping Zhang, Xinlei Chen†
ACM UbiComp CPD, 2023
Uses reinforcement learning to generate smooth trajectories for quadrotor landing.
2022
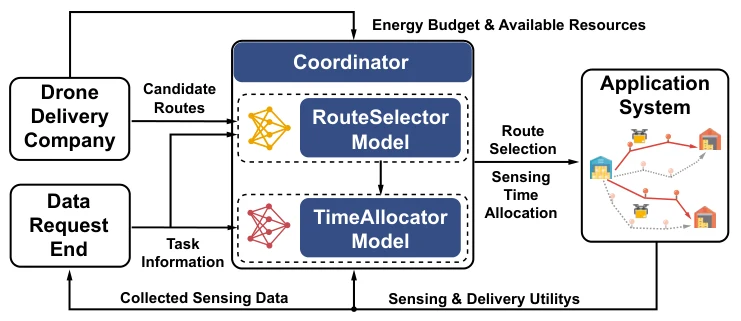
DeliverSense: Efficient delivery drone scheduling for crowdsensing with deep reinforcement learning
Xuecheng Chen, Haoyang Wang, Zuxin Li, Wenbo Ding, Fan Dang, Chengye Wu, Xinlei Chen†
ACM UbiComp CPD, 2022
Uses deep reinforcement learning to schedule delivery drones for crowdsensing.
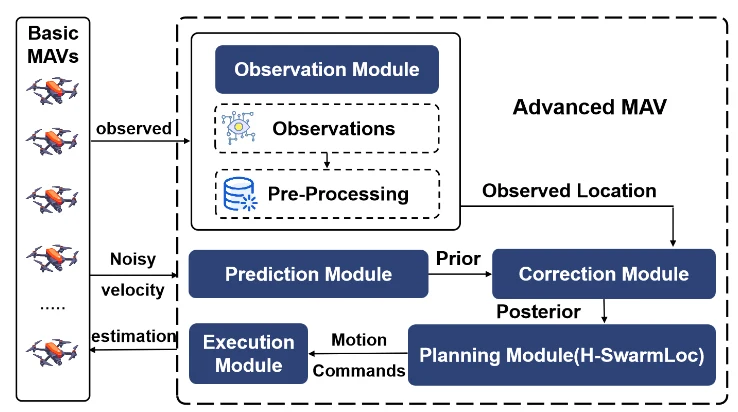
H-SwarmLoc: efficient scheduling for localization of heterogeneous MAV swarm with deep reinforcement learning
Haoyang Wang*, Xuecheng Chen*, Yuhan Cheng, Chenye Wu, Fan Dang, Xinlei Chen†
ACM SenSys CML-IoT, 2022
Learns efficient localization schedules for heterogeneous drone swarms through deep reinforcement learning.
2021
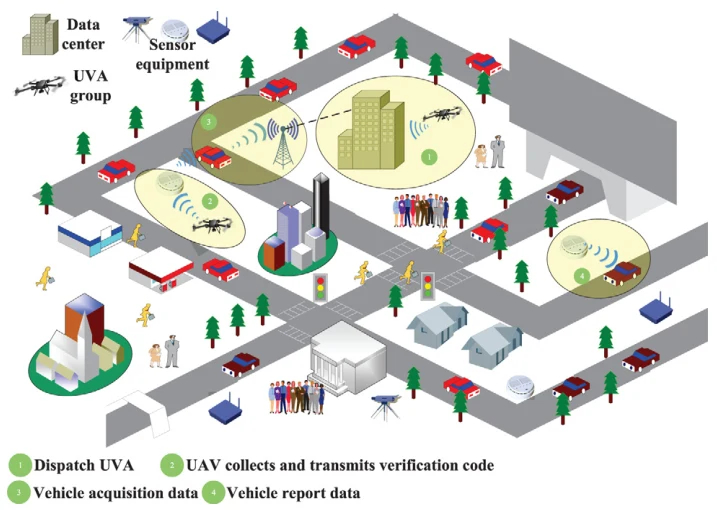
A lightweight verifiable trust based data collection approach for sensor--cloud systems
Jiawei Guo, Haoyang Wang, Wei Liu, Guosheng Huang, Jinsong Gui, Shaobo Zhang
Journal of Systems Architecture, 2021
Combines trust assessment and verification for lightweight data collection in sensor-cloud systems.